updates before supervision-0.26.0 release
This commit is contained in:
 SkalskiP committed
1 parent
4948612cd4
commit
0f56a405c6
4 files changed
+106
-86
No files matched your search
+80
-49
@@ -8,67 +8,65 @@
|
||||
!!! info "Tip"
|
||||
Supervision’s documentation theme now has a fresh look that is consistent with the documentations of all Roboflow open-source projects. ([#1858](https://github.com/roboflow/supervision/pull/1858))
|
||||
|
||||
- Added [#1774](https://github.com/roboflow/supervision/pull/1774): Support for IOS overlap metric (a region-overlap score between two shapes that indicates how much of the smaller object is covered by the bigger one) for `sv.Detections.with_nms` and `sv.Detections.with_nmm`, `sv.box_iou_batch`, and `sv.mask_iou_batch`.
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov11m-seg-640")
|
||||
image = cv2.imread("<IMAGE-PATH>")
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
detections = detections.with_nmm(overlap_metric=sv.OverlapMetric.IOU)
|
||||
```
|
||||
|
||||
- Added [#1874](https://github.com/roboflow/supervision/pull/1874): `sv.box_iou` that efficiently computes the Intersection over Union (IoU) between two individual bounding boxes.
|
||||
|
||||
- Added [#1816](https://github.com/roboflow/supervision/pull/1816): Support for frame limitations and progress bar in `sv.process_video`.
|
||||
- Added [#1774](https://github.com/roboflow/supervision/pull/1774): Support for the IOS (Intersection over Smallest) overlap metric that measures how much of the smaller object is covered by the larger one in [`sv.Detections.with_nms`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.with_nms), [`sv.Detections.with_nmm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.with_nmm), [`sv.box_iou_batch`](https://supervision.roboflow.com/0.26.0/detection/utils/iou_and_nms/#supervision.detection.utils.iou_and_nms.box_iou_batch), and [`sv.mask_iou_batch`](https://supervision.roboflow.com/0.26.0/detection/utils/iou_and_nms/#supervision.detection.utils.iou_and_nms.mask_iou_batch).
|
||||
|
||||
```python
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model("yolov11m-640")
|
||||
box_annotator = sv.BoxAnnotator()
|
||||
|
||||
def callback(frame: np.ndarray, _: int) -> np.ndarray:
|
||||
results = model.infer(frame,verbose=False)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
return box_annotator.annotate(frame.copy(), detections=detections)
|
||||
|
||||
sv.process_video(
|
||||
source_path="<SOURCE-VIDEO-PATH>",
|
||||
target_path="<TARGET-VIDEO-PATH>",
|
||||
callback=callback,
|
||||
max_frames=100,
|
||||
show_progress=True,
|
||||
|
||||
boxes_true = np.array([
|
||||
[100, 100, 200, 200],
|
||||
[300, 300, 400, 400]
|
||||
])
|
||||
boxes_detection = np.array([
|
||||
[150, 150, 250, 250],
|
||||
[320, 320, 420, 420]
|
||||
])
|
||||
|
||||
sv.box_iou_batch(
|
||||
boxes_true=boxes_true,
|
||||
boxes_detection=boxes_detection,
|
||||
overlap_metric=sv.OverlapMetric.IOU
|
||||
)
|
||||
|
||||
# array([[0.14285714, 0. ],
|
||||
# [0. , 0.47058824]])
|
||||
|
||||
sv.box_iou_batch(
|
||||
boxes_true=boxes_true,
|
||||
boxes_detection=boxes_detection,
|
||||
overlap_metric=sv.OverlapMetric.IOS
|
||||
)
|
||||
|
||||
# array([[0.25, 0. ],
|
||||
# [0. , 0.64]])
|
||||
```
|
||||
|
||||
- Added [#1788](https://github.com/roboflow/supervision/pull/1788): Support for creating `sv.KeyPoints` objects using [ViTPose](https://huggingface.co/docs/transformers/en/model_doc/vitpose) and [ViTPose++](https://huggingface.co/docs/transformers/en/model_doc/vitpose#vitpose-models) inference results from [Transformers](https://huggingface.co/docs/transformers/index).
|
||||
- Added [#1874](https://github.com/roboflow/supervision/pull/1874): [`sv.box_iou`](https://supervision.roboflow.com/0.26.0/detection/utils/iou_and_nms/#supervision.detection.utils.iou_and_nms.box_iou) that efficiently computes the Intersection over Union (IoU) between two individual bounding boxes.
|
||||
|
||||
- Added [#1823](https://github.com/roboflow/supervision/pull/1823): `sv.xyxy_to_xcycarh` function to convert bounding box coordinates from `(x_min, y_min, x_max, y_max)` into measurement space to format `(center x, center y, aspect ratio, height)`, where the aspect ratio is `width / height`.
|
||||
- Added [#1816](https://github.com/roboflow/supervision/pull/1816): Support for frame limitations and progress bar in [`sv.process_video`](https://supervision.roboflow.com/0.26.0/utils/video/#supervision.utils.video.process_video).
|
||||
|
||||
- Added [#1788](https://github.com/roboflow/supervision/pull/1788): `sv.xyxy_to_xywh` function to convert bounding box coordinates from `(x_min, y_min, x_max, y_max)` format to `(x, y, width, height)` format.
|
||||
- Added [#1788](https://github.com/roboflow/supervision/pull/1788): Support for creating [`sv.KeyPoints`](https://supervision.roboflow.com/0.26.0/keypoint/core/#supervision.keypoint.core.KeyPoints) objects from [ViTPose](https://huggingface.co/docs/transformers/en/model_doc/vitpose) and [ViTPose++](https://huggingface.co/docs/transformers/en/model_doc/vitpose#vitpose-models) inference results via [`sv.KeyPoints.from_transformers`](https://supervision.roboflow.com/0.26.0/keypoint/core/#supervision.keypoint.core.KeyPoints.from_transformers).
|
||||
|
||||
- Changed [#1820](https://github.com/roboflow/supervision/pull/1820): `sv.LabelAnnotator` now has the ability to ensure labels stay within frame boundaries using the smart_position parameter and control automatic text wrapping for long multi-line labels using the max_line_length parameter.
|
||||
- Added [#1823](https://github.com/roboflow/supervision/pull/1823): [`sv.xyxy_to_xcycarh`](https://supervision.roboflow.com/0.26.0/detection/utils/converters/#supervision.detection.utils.converters.xyxy_to_xcycarh) function to convert bounding box coordinates from `(x_min, y_min, x_max, y_max)` into measurement space to format `(center x, center y, aspect ratio, height)`, where the aspect ratio is `width / height`.
|
||||
|
||||
- Changed [#1825](https://github.com/roboflow/supervision/pull/1825): `sv.LabelAnnotator` now supports non-string labels.
|
||||
- Added [#1788](https://github.com/roboflow/supervision/pull/1788): [`sv.xyxy_to_xywh`](https://supervision.roboflow.com/0.26.0/detection/utils/converters/#supervision.detection.utils.converters.xyxy_to_xywh) function to convert bounding box coordinates from `(x_min, y_min, x_max, y_max)` format to `(x, y, width, height)` format.
|
||||
|
||||
- Changed [#1792](https://github.com/roboflow/supervision/pull/1792): `sv.Detections.from_vlm` now supports bounding boxes and segmentation masks response from [Google Gemini models](https://ai.google.dev/gemini-api/docs/vision).
|
||||
- Changed [#1820](https://github.com/roboflow/supervision/pull/1820): [`sv.LabelAnnotator`](https://supervision.roboflow.com/0.26.0/detection/annotators/#supervision.annotators.core.LabelAnnotator) now supports the `smart_position` parameter to automatically keep labels within frame boundaries, and the `max_line_length` parameter to control text wrapping for long or multi-line labels.
|
||||
|
||||
- Changed [#1825](https://github.com/roboflow/supervision/pull/1825): [`sv.LabelAnnotator`](https://supervision.roboflow.com/0.26.0/detection/annotators/#supervision.annotators.core.LabelAnnotator) now supports non-string labels.
|
||||
|
||||
- Changed [#1792](https://github.com/roboflow/supervision/pull/1792): [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) now supports parsing bounding boxes and segmentation masks from responses generated by [Google Gemini models](https://ai.google.dev/gemini-api/docs/vision).
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
gemini_response_text = \"\"\"```json
|
||||
gemini_response_text = """```json
|
||||
[
|
||||
{"box_2d": [543, 40, 728, 200], "label": "cat", "id": 1},
|
||||
{"box_2d": [653, 352, 820, 522], "label": "dog", "id": 2}
|
||||
]
|
||||
```\"\"\"
|
||||
```"""
|
||||
|
||||
detections = sv.Detections.from_vlm(
|
||||
sv.VLM.GOOGLE_GEMINI_2_5,
|
||||
@@ -76,9 +74,18 @@
|
||||
resolution_wh=(1000, 1000),
|
||||
classes=['cat', 'dog'],
|
||||
)
|
||||
|
||||
detections.xyxy
|
||||
# array([[543., 40., 728., 200.], [653., 352., 820., 522.]])
|
||||
|
||||
detections.data
|
||||
# {'class_name': array(['cat', 'dog'], dtype='<U26')}
|
||||
|
||||
detections.class_id
|
||||
# array([0, 1])
|
||||
```
|
||||
|
||||
- Changed [#1878](https://github.com/roboflow/supervision/pull/1878): `sv.Detections.from_vlm` now supports bounding boxes response from [Moondream](https://github.com/vikhyat/moondream).
|
||||
- Changed [#1878](https://github.com/roboflow/supervision/pull/1878): [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) now supports parsing bounding boxes from responses generated by [Moondream](https://github.com/vikhyat/moondream).
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
@@ -105,19 +112,24 @@
|
||||
moondream_result,
|
||||
resolution_wh=(1000, 1000),
|
||||
)
|
||||
|
||||
detections.xyxy
|
||||
# array([[1752.28, 818.82, 2165.72, 1229.14],
|
||||
# [1908.01, 1346.67, 2585.99, 2024.11]])
|
||||
```
|
||||
|
||||
- Changed [#1709](https://github.com/roboflow/supervision/pull/1790): `sv.Detections.from_vlm` now supports bounding boxes response from [Qwen-2.5 VL](https://github.com/QwenLM/Qwen2.5-VL).
|
||||
- Changed [#1709](https://github.com/roboflow/supervision/pull/1790): [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) now supports parsing bounding boxes from responses generated by [Qwen-2.5 VL](https://github.com/QwenLM/Qwen2.5-VL).
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
qwen_2_5_vl_result = \"\"\"```json
|
||||
qwen_2_5_vl_result = """```json
|
||||
[
|
||||
{"bbox_2d": [139, 768, 315, 954], "label": "cat"},
|
||||
{"bbox_2d": [366, 679, 536, 849], "label": "dog"}
|
||||
]
|
||||
```\"\"\"
|
||||
```"""
|
||||
|
||||
detections = sv.Detections.from_vlm(
|
||||
sv.VLM.QWEN_2_5_VL,
|
||||
qwen_2_5_vl_result,
|
||||
@@ -125,11 +137,23 @@
|
||||
resolution_wh=(1000, 1000),
|
||||
classes=['cat', 'dog'],
|
||||
)
|
||||
|
||||
detections.xyxy
|
||||
# array([[139., 768., 315., 954.], [366., 679., 536., 849.]])
|
||||
|
||||
detections.class_id
|
||||
# array([0, 1])
|
||||
|
||||
detections.data
|
||||
# {'class_name': array(['cat', 'dog'], dtype='<U10')}
|
||||
|
||||
detections.class_id
|
||||
# array([0, 1])
|
||||
```
|
||||
|
||||
- Changed [#1786](https://github.com/roboflow/supervision/pull/1786): Improved the speed of HSV color mapping in `sv.HeatMapAnnotator` massively, improving the performance of the operation on a 1920x1080 frame by ~28x.
|
||||
- Changed [#1786](https://github.com/roboflow/supervision/pull/1786): Significantly improved the speed of HSV color mapping in [`sv.HeatMapAnnotator`](https://supervision.roboflow.com/0.26.0/detection/annotators/#supervision.annotators.core.HeatMapAnnotator), achieving approximately 28x faster performance on 1920x1080 frames.
|
||||
|
||||
- Fix [#1834](https://github.com/roboflow/supervision/pull/1834): Supervision's mAP implementation (`sv.MeanAveragePrecision`) has been aligned with [pycocotools](https://github.com/ppwwyyxx/cocoapi), the official COCO evaluation tool, thus ensuring accurate, reliable, and standardized metrics. This enabled us to build an updated version of the [Computer Vision Model Leaderboard](https://leaderboard.roboflow.com/).
|
||||
- Fix [#1834](https://github.com/roboflow/supervision/pull/1834): Supervision’s [`sv.MeanAveragePrecision`](https://supervision.roboflow.com/0.26.0/metrics/mean_average_precision/#supervision.metrics.mean_average_precision.MeanAveragePrecision) is now fully aligned with [pycocotools](https://github.com/ppwwyyxx/cocoapi), the official COCO evaluation tool, ensuring accurate and standardized metrics. This update enabled us to launch a new version of the [Computer Vision Model Leaderboard](https://leaderboard.roboflow.com/).
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
@@ -139,10 +163,17 @@
|
||||
targets = sv.Detections(...)
|
||||
|
||||
map_metric = MeanAveragePrecision()
|
||||
map_score = map_metric.update(predictions, targets).compute()
|
||||
map_metric.update(predictions, targets).compute()
|
||||
|
||||
# Average Precision (AP) @[ IoU=0.50:0.95 | area= all | maxDets=100 ] = 0.464
|
||||
# Average Precision (AP) @[ IoU=0.50 | area= all | maxDets=100 ] = 0.637
|
||||
# Average Precision (AP) @[ IoU=0.75 | area= all | maxDets=100 ] = 0.203
|
||||
# Average Precision (AP) @[ IoU=0.50:0.95 | area= small | maxDets=100 ] = 0.284
|
||||
# Average Precision (AP) @[ IoU=0.50:0.95 | area=medium | maxDets=100 ] = 0.497
|
||||
# Average Precision (AP) @[ IoU=0.50:0.95 | area= large | maxDets=100 ] = 0.629
|
||||
```
|
||||
|
||||
- Fix [#1767](https://github.com/roboflow/supervision/pull/1767): Fixed losing `sv.Detections.data` when detections filtering.
|
||||
- Fix [#1767](https://github.com/roboflow/supervision/pull/1767): Fixed losing `sv.Detections.data` when detections filtering.
|
||||
|
||||
### 0.25.0 <small>Nov 12, 2024</small>
|
||||
|
||||
|
||||
+11
-21
@@ -7,29 +7,19 @@ status: deprecated
|
||||
|
||||
These features are phased out due to better alternatives or potential issues in future versions. Deprecated functionalities are supported for **five subsequent releases**, providing time for users to transition to updated methods.
|
||||
|
||||
- Constructing [`DetectionDataset`](https://supervision.roboflow.com/latest/datasets/core/#supervision.dataset.core.DetectionDataset) and [`ClassificationDataset`](https://supervision.roboflow.com/latest/datasets/core/#supervision.dataset.core.ClassificationDataset) with parameter `images` as `Dict[str, np.ndarray]` will be removed in `supervision-0.26.0`. Please pass a list of paths `List[str]` instead.
|
||||
|
||||
- The `DetectionDataset.images` property will be removed in `supervision-0.26.0`. Please loop over images with `for path, image, annotation in dataset:`, as that does not require loading all images into memory.
|
||||
|
||||
- `BoundingBoxAnnotator` has been renamed to `BoxAnnotator` after the old implementation of [`BoxAnnotator`](https://supervision.roboflow.com/latest/detection/annotators/#supervision.annotators.core.BoxAnnotator) has been removed. `BoundingBoxAnnotator` will be removed in `supervision-0.26.0`.
|
||||
|
||||
- `overlap_filter_strategy` in [`InferenceSlicer.__init__`](https://supervision.roboflow.com/latest/detection/tools/inference_slicer/) is deprecated and will be removed in `supervision-0.27.0`. Use `overlap_strategy` instead.
|
||||
|
||||
- `overlap_ratio_wh` in [`InferenceSlicer.__init__`](https://supervision.roboflow.com/latest/detection/tools/inference_slicer/) is deprecated and will be removed in `supervision-0.27.0`. Use `overlap_wh` instead.
|
||||
- `sv.LMM` enum is deprecated and will be removed in `supervision-0.31.0`. Use `sv.VLM` instead.
|
||||
- [`sv.Detections.from_lmm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_lmm) property is deprecated and will be removed in `supervision-0.31.0`. Use [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) instead.
|
||||
|
||||
# Removed
|
||||
|
||||
### 0.26.0
|
||||
|
||||
- The `sv.DetectionDataset.images` property has been removed in `supervision-0.26.0`. Please loop over images with `for path, image, annotation in dataset:`, as that does not require loading all images into memory. Also, constructing `sv.DetectionDataset` with parameter `images` as `Dict[str, np.ndarray]` is deprecated and has been removed in `supervision-0.26.0`. Please pass a list of paths `List[str]` instead.
|
||||
|
||||
- The name `sv.BoundingBoxAnnotator` is deprecated and has been removed in `supervision-0.26.0`. It has been renamed to [`sv.BoxAnnotator`](https://supervision.roboflow.com/0.22.0/detection/annotators/#supervision.annotators.core.BoxAnnotator).
|
||||
|
||||
- `supervision-0.26.0` drops `python3.8` support and upgrade all codes to `python3.9` syntax style.
|
||||
|
||||
### 0.25.0
|
||||
|
||||
No removals in this version!
|
||||
|
||||
### 0.24.0
|
||||
|
||||
@@ -43,12 +33,12 @@ No removals in this version!
|
||||
|
||||
### 0.22.0
|
||||
|
||||
- `Detections.from_roboflow` is removed as of `supervision-0.22.0`. Use [`Detections.from_inference`](detection/core.md/#supervision.detection.core.Detections.from_inference) instead.
|
||||
- The method `Color.white()` was removed as of `supervision-0.22.0`. Use the constant `Color.WHITE` instead.
|
||||
- The method `Color.black()` was removed as of `supervision-0.22.0`. Use the constant `Color.BLACK` instead.
|
||||
- The method `Color.red()` was removed as of `supervision-0.22.0`. Use the constant `Color.RED` instead.
|
||||
- The method `Color.green()` was removed as of `supervision-0.22.0`. Use the constant `Color.GREEN` instead.
|
||||
- The method `Color.blue()` was removed as of `supervision-0.22.0`. Use the constant `Color.BLUE` instead.
|
||||
- The method `ColorPalette.default()` was removed as of `supervision-0.22.0`. Use the constant [`ColorPalette.DEFAULT`](/utils/draw/#supervision.draw.color.ColorPalette.DEFAULT) instead.
|
||||
- `BoxAnnotator` was removed as of `supervision-0.22.0`, however `BoundingBoxAnnotator` was immediately renamed to `BoxAnnotator`. Use [`BoxAnnotator`](detection/annotators.md/#supervision.annotators.core.BoxAnnotator) and [`LabelAnnotator`](detection/annotators.md/#supervision.annotators.core.LabelAnnotator) instead of the old `BoxAnnotator`.
|
||||
- The method `FPSMonitor.__call__` was removed as of `supervision-0.22.0`. Use the attribute [`FPSMonitor.fps`](utils/video.md/#supervision.utils.video.FPSMonitor.fps) instead.
|
||||
- `sv.Detections.from_roboflow` is removed as of `supervision-0.22.0`. Use [`Detections.from_inference`](detection/core.md/#supervision.detection.core.Detections.from_inference) instead.
|
||||
- The method `sv.Color.white()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.WHITE` instead.
|
||||
- The method `sv.Color.black()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.BLACK` instead.
|
||||
- The method `sv.Color.red()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.RED` instead.
|
||||
- The method `sv.Color.green()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.GREEN` instead.
|
||||
- The method `sv.Color.blue()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.BLUE` instead.
|
||||
- The method `sv.ColorPalette.default()` was removed as of `supervision-0.22.0`. Use the constant [`ColorPalette.DEFAULT`](/utils/draw/#supervision.draw.color.ColorPalette.DEFAULT) instead.
|
||||
- `sv.BoxAnnotator` was removed as of `supervision-0.22.0`, however `sv.BoundingBoxAnnotator` was immediately renamed to `sv.BoxAnnotator`. Use [`BoxAnnotator`](detection/annotators.md/#supervision.annotators.core.BoxAnnotator) and [`LabelAnnotator`](detection/annotators.md/#supervision.annotators.core.LabelAnnotator) instead of the old `sv.BoxAnnotator`.
|
||||
- The method `sv.FPSMonitor.__call__` was removed as of `supervision-0.22.0`. Use the attribute [`sv.FPSMonitor.fps`](utils/video.md/#supervision.utils.video.FPSMonitor.fps) instead.
|
||||
@@ -28,28 +28,26 @@ Annotators accept detections and apply box or mask visualizations to the detecti
|
||||
|
||||
</div>
|
||||
|
||||
<!--
|
||||
=== "RoundBox"
|
||||
=== "RoundBox"
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
detections = sv.Detections(...)
|
||||
image = ...
|
||||
detections = sv.Detections(...)
|
||||
|
||||
round_box_annotator = sv.RoundBoxAnnotator()
|
||||
annotated_frame = round_box_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
)
|
||||
```
|
||||
round_box_annotator = sv.RoundBoxAnnotator()
|
||||
annotated_frame = round_box_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
)
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
<div class="result" markdown>
|
||||
|
||||
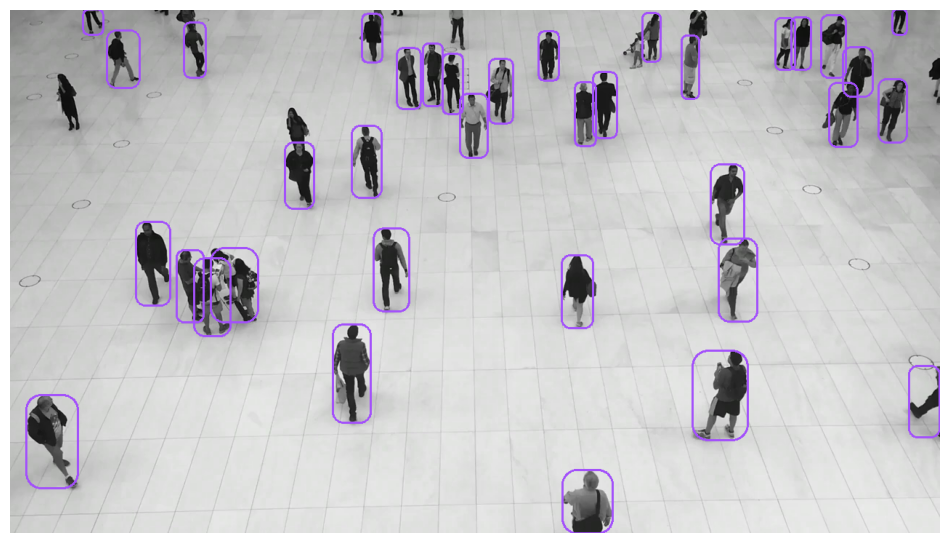{ align=center width="800" }
|
||||
{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
-->
|
||||
</div>
|
||||
|
||||
=== "BoxCorner"
|
||||
|
||||
|
||||
@@ -1,5 +1,6 @@
|
||||
---
|
||||
comments: true
|
||||
status: new
|
||||
---
|
||||
|
||||
# Keypoint Detection
|
||||
|
||||
Reference in new issue
Block a user