Merge pull request #406 from roboflow/feature/annotators-refactor-before-0.15.0-release
Refactor TraceAnnotator to separate utility class
This commit is contained in:

7 files changed
+206
-166
No files matched your search
@@ -124,6 +124,27 @@
|
||||
|
||||
</div>
|
||||
|
||||
=== "Trace"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> trace_annotator = sv.TraceAnnotator()
|
||||
>>> annotated_frame = trace_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
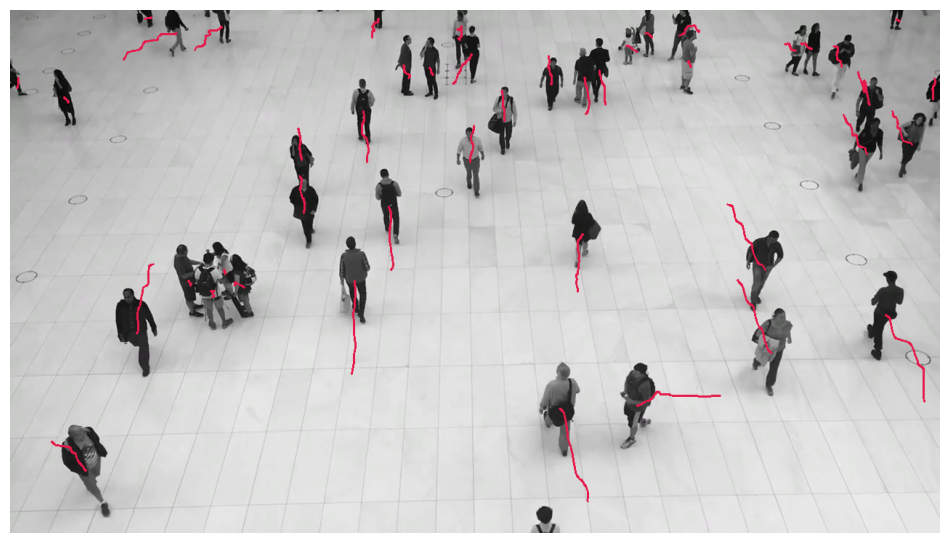{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
## BoundingBoxAnnotator
|
||||
|
||||
:::supervision.annotators.core.BoundingBoxAnnotator
|
||||
@@ -147,3 +168,7 @@
|
||||
## LabelAnnotator
|
||||
|
||||
:::supervision.annotators.core.LabelAnnotator
|
||||
|
||||
## TraceAnnotator
|
||||
|
||||
:::supervision.annotators.core.TraceAnnotator
|
||||
@@ -13,6 +13,7 @@ from supervision.annotators.core import (
|
||||
EllipseAnnotator,
|
||||
LabelAnnotator,
|
||||
MaskAnnotator,
|
||||
TraceAnnotator,
|
||||
)
|
||||
from supervision.classification.core import Classifications
|
||||
from supervision.dataset.core import (
|
||||
@@ -20,7 +21,7 @@ from supervision.dataset.core import (
|
||||
ClassificationDataset,
|
||||
DetectionDataset,
|
||||
)
|
||||
from supervision.detection.annotate import BoxAnnotator, TraceAnnotator
|
||||
from supervision.detection.annotate import BoxAnnotator
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.detection.line_counter import LineZone, LineZoneAnnotator
|
||||
from supervision.detection.tools.inference_slicer import InferenceSlicer
|
||||
|
||||
@@ -1,55 +1,8 @@
|
||||
from abc import ABC, abstractmethod
|
||||
from enum import Enum
|
||||
from typing import Union
|
||||
|
||||
import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
|
||||
|
||||
class ColorMap(Enum):
|
||||
"""
|
||||
Enum for annotator color mapping.
|
||||
"""
|
||||
|
||||
INDEX = "index"
|
||||
CLASS = "class"
|
||||
TRACK = "track"
|
||||
|
||||
|
||||
def resolve_color_idx(
|
||||
detections: Detections, detection_idx: int, color_map: ColorMap = ColorMap.CLASS
|
||||
) -> int:
|
||||
if detection_idx >= len(detections):
|
||||
raise ValueError(
|
||||
f"Detection index {detection_idx}"
|
||||
f"is out of bounds for detections of length {len(detections)}"
|
||||
)
|
||||
|
||||
if color_map == ColorMap.INDEX:
|
||||
return detection_idx
|
||||
elif color_map == ColorMap.CLASS:
|
||||
if detections.class_id is None:
|
||||
raise ValueError(
|
||||
"Could not resolve color by class because"
|
||||
"Detections do not have class_id"
|
||||
)
|
||||
return detections.class_id[detection_idx]
|
||||
elif color_map == ColorMap.TRACK:
|
||||
if detections.tracker_id is None:
|
||||
raise ValueError(
|
||||
"Could not resolve color by track because"
|
||||
"Detections do not have tracker_id"
|
||||
)
|
||||
return detections.tracker_id[detection_idx]
|
||||
|
||||
|
||||
def resolve_color(color: Union[Color, ColorPalette], idx: int) -> Color:
|
||||
if isinstance(color, ColorPalette):
|
||||
return color.by_idx(idx)
|
||||
else:
|
||||
return color
|
||||
|
||||
|
||||
class BaseAnnotator(ABC):
|
||||
|
||||
@@ -1,12 +1,13 @@
|
||||
from math import sqrt
|
||||
from typing import List, Tuple, Union
|
||||
from typing import List, Optional, Tuple, Union
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
||||
from supervision.annotators.base import (
|
||||
BaseAnnotator,
|
||||
from supervision.annotators.base import BaseAnnotator
|
||||
from supervision.annotators.utils import (
|
||||
ColorMap,
|
||||
Trace,
|
||||
resolve_color,
|
||||
resolve_color_idx,
|
||||
)
|
||||
@@ -562,3 +563,88 @@ class LabelAnnotator:
|
||||
lineType=cv2.LINE_AA,
|
||||
)
|
||||
return scene
|
||||
|
||||
|
||||
class TraceAnnotator:
|
||||
"""
|
||||
A class for drawing trace paths on an image based on detection coordinates.
|
||||
|
||||
!!! warning
|
||||
|
||||
This annotator utilizes the `tracker_id`. Read
|
||||
[here](https://supervision.roboflow.com/trackers/) to learn how to plug
|
||||
tracking into your inference pipeline.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
position: Optional[Position] = Position.CENTER,
|
||||
trace_length: int = 30,
|
||||
thickness: int = 2,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
color (Union[Color, ColorPalette]): The color to draw the trace, can be
|
||||
a single color or a color palette.
|
||||
position (Optional[Position]): The position of the trace.
|
||||
Defaults to `CENTER`.
|
||||
trace_length (int): The maximum length of the trace in terms of historical
|
||||
points. Defaults to `30`.
|
||||
thickness (int): The thickness of the trace lines. Defaults to `2`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.position = position
|
||||
self.trace = Trace(max_size=trace_length)
|
||||
self.thickness = thickness
|
||||
|
||||
def annotate(self, scene: np.ndarray, detections: Detections) -> np.ndarray:
|
||||
"""
|
||||
Draws trace paths on the frame based on the detection coordinates provided.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image on which the traces will be drawn.
|
||||
detections (Detections): The detections which include coordinates for
|
||||
which the traces will be drawn.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The image with the trace paths drawn on it.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> trace_annotator = sv.TraceAnnotator()
|
||||
>>> annotated_frame = trace_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||

|
||||
"""
|
||||
self.trace.put(detections)
|
||||
|
||||
for i, (xyxy, mask, confidence, class_id, tracker_id) in enumerate(detections):
|
||||
class_id = detections.class_id[i] if class_id is not None else None
|
||||
idx = class_id if class_id is not None else i
|
||||
color = (
|
||||
self.color.by_idx(idx)
|
||||
if isinstance(self.color, ColorPalette)
|
||||
else self.color
|
||||
)
|
||||
|
||||
xy = self.trace.get(tracker_id=tracker_id)
|
||||
if len(xy) > 1:
|
||||
scene = cv2.polylines(
|
||||
scene,
|
||||
[xy.astype(np.int32)],
|
||||
False,
|
||||
color=color.as_bgr(),
|
||||
thickness=self.thickness,
|
||||
)
|
||||
return scene
|
||||
@@ -0,0 +1,89 @@
|
||||
from enum import Enum
|
||||
from typing import Optional, Union
|
||||
|
||||
import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.geometry.core import Position
|
||||
|
||||
|
||||
class ColorMap(Enum):
|
||||
"""
|
||||
Enum for annotator color mapping.
|
||||
"""
|
||||
|
||||
INDEX = "index"
|
||||
CLASS = "class"
|
||||
TRACK = "track"
|
||||
|
||||
|
||||
def resolve_color_idx(
|
||||
detections: Detections, detection_idx: int, color_map: ColorMap = ColorMap.CLASS
|
||||
) -> int:
|
||||
if detection_idx >= len(detections):
|
||||
raise ValueError(
|
||||
f"Detection index {detection_idx}"
|
||||
f"is out of bounds for detections of length {len(detections)}"
|
||||
)
|
||||
|
||||
if color_map == ColorMap.INDEX:
|
||||
return detection_idx
|
||||
elif color_map == ColorMap.CLASS:
|
||||
if detections.class_id is None:
|
||||
raise ValueError(
|
||||
"Could not resolve color by class because"
|
||||
"Detections do not have class_id"
|
||||
)
|
||||
return detections.class_id[detection_idx]
|
||||
elif color_map == ColorMap.TRACK:
|
||||
if detections.tracker_id is None:
|
||||
raise ValueError(
|
||||
"Could not resolve color by track because"
|
||||
"Detections do not have tracker_id"
|
||||
)
|
||||
return detections.tracker_id[detection_idx]
|
||||
|
||||
|
||||
def resolve_color(color: Union[Color, ColorPalette], idx: int) -> Color:
|
||||
if isinstance(color, ColorPalette):
|
||||
return color.by_idx(idx)
|
||||
return color
|
||||
|
||||
|
||||
class Trace:
|
||||
def __init__(
|
||||
self,
|
||||
max_size: Optional[int] = None,
|
||||
start_frame_id: int = 0,
|
||||
anchor: Position = Position.CENTER,
|
||||
) -> None:
|
||||
self.current_frame_id = start_frame_id
|
||||
self.max_size = max_size
|
||||
self.anchor = anchor
|
||||
|
||||
self.frame_id = np.array([], dtype=int)
|
||||
self.xy = np.empty((0, 2), dtype=np.float32)
|
||||
self.tracker_id = np.array([], dtype=int)
|
||||
|
||||
def put(self, detections: Detections) -> None:
|
||||
frame_id = np.full(len(detections), self.current_frame_id, dtype=int)
|
||||
self.frame_id = np.concatenate([self.frame_id, frame_id])
|
||||
self.xy = np.concatenate(
|
||||
[self.xy, detections.get_anchor_coordinates(self.anchor)]
|
||||
)
|
||||
self.tracker_id = np.concatenate([self.tracker_id, detections.tracker_id])
|
||||
|
||||
unique_frame_id = np.unique(self.frame_id)
|
||||
|
||||
if 0 < self.max_size < len(unique_frame_id):
|
||||
max_allowed_frame_id = self.current_frame_id - self.max_size + 1
|
||||
filtering_mask = self.frame_id >= max_allowed_frame_id
|
||||
self.frame_id = self.frame_id[filtering_mask]
|
||||
self.xy = self.xy[filtering_mask]
|
||||
self.tracker_id = self.tracker_id[filtering_mask]
|
||||
|
||||
self.current_frame_id += 1
|
||||
|
||||
def get(self, tracker_id: int) -> np.ndarray:
|
||||
return self.xy[self.tracker_id == tracker_id]
|
||||
@@ -5,7 +5,6 @@ import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.geometry.core import Position
|
||||
|
||||
|
||||
class BoxAnnotator:
|
||||
@@ -145,116 +144,3 @@ class BoxAnnotator:
|
||||
lineType=cv2.LINE_AA,
|
||||
)
|
||||
return scene
|
||||
|
||||
|
||||
class Trace:
|
||||
def __init__(
|
||||
self,
|
||||
max_size: Optional[int] = None,
|
||||
start_frame_id: int = 0,
|
||||
anchor: Position = Position.CENTER,
|
||||
) -> None:
|
||||
self.current_frame_id = start_frame_id
|
||||
self.max_size = max_size
|
||||
self.anchor = anchor
|
||||
|
||||
self.frame_id = np.array([], dtype=int)
|
||||
self.xy = np.empty((0, 2), dtype=np.float32)
|
||||
self.tracker_id = np.array([], dtype=int)
|
||||
|
||||
def put(self, detections: Detections) -> None:
|
||||
frame_id = np.full(len(detections), self.current_frame_id, dtype=int)
|
||||
self.frame_id = np.concatenate([self.frame_id, frame_id])
|
||||
self.xy = np.concatenate(
|
||||
[self.xy, detections.get_anchor_coordinates(self.anchor)]
|
||||
)
|
||||
self.tracker_id = np.concatenate([self.tracker_id, detections.tracker_id])
|
||||
|
||||
unique_frame_id = np.unique(self.frame_id)
|
||||
|
||||
if 0 < self.max_size < len(unique_frame_id):
|
||||
max_allowed_frame_id = self.current_frame_id - self.max_size + 1
|
||||
filtering_mask = self.frame_id >= max_allowed_frame_id
|
||||
self.frame_id = self.frame_id[filtering_mask]
|
||||
self.xy = self.xy[filtering_mask]
|
||||
self.tracker_id = self.tracker_id[filtering_mask]
|
||||
|
||||
self.current_frame_id += 1
|
||||
|
||||
def get(self, tracker_id: int) -> np.ndarray:
|
||||
return self.xy[self.tracker_id == tracker_id]
|
||||
|
||||
|
||||
class TraceAnnotator:
|
||||
"""
|
||||
A class for drawing trace paths on an image based on detection coordinates.
|
||||
|
||||
Attributes:
|
||||
color (Union[Color, ColorPalette]): The color to draw the trace, can be
|
||||
a single color or a color palette.
|
||||
position (Optional[Position]): The position of the trace. Defaults to `CENTER`.
|
||||
trace_length (int): The maximum length of the trace in terms of historical
|
||||
points. Defaults to `30`.
|
||||
thickness (int): The thickness of the trace lines. Defaults to `2`.
|
||||
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
position: Optional[Position] = Position.CENTER,
|
||||
trace_length: int = 30,
|
||||
thickness: int = 2,
|
||||
):
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.position = position
|
||||
self.trace = Trace(max_size=trace_length)
|
||||
self.thickness = thickness
|
||||
|
||||
def annotate(self, scene: np.ndarray, detections: Detections) -> np.ndarray:
|
||||
"""
|
||||
Draws trace paths on the frame based on the detection coordinates provided.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image on which the traces will be drawn.
|
||||
detections (Detections): The detections which include coordinates for
|
||||
which the traces will be drawn.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The image with the trace paths drawn on it.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> trace_annotator = sv.TraceAnnotator()
|
||||
>>> annotated_frame = trace_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
"""
|
||||
self.trace.put(detections)
|
||||
|
||||
for i, (xyxy, mask, confidence, class_id, tracker_id) in enumerate(detections):
|
||||
class_id = detections.class_id[i] if class_id is not None else None
|
||||
idx = class_id if class_id is not None else i
|
||||
color = (
|
||||
self.color.by_idx(idx)
|
||||
if isinstance(self.color, ColorPalette)
|
||||
else self.color
|
||||
)
|
||||
|
||||
xy = self.trace.get(tracker_id=tracker_id)
|
||||
if len(xy) > 1:
|
||||
scene = cv2.polylines(
|
||||
scene,
|
||||
[xy.astype(np.int32)],
|
||||
False,
|
||||
color=color.as_bgr(),
|
||||
thickness=self.thickness,
|
||||
)
|
||||
return scene
|
||||
@@ -4,7 +4,7 @@ from typing import Optional
|
||||
|
||||
import pytest
|
||||
|
||||
from supervision.annotators.core import ColorMap, resolve_color_idx
|
||||
from supervision.annotators.utils import ColorMap, resolve_color_idx
|
||||
from supervision.detection.core import Detections
|
||||
|
||||
|
||||
Reference in new issue
Block a user