Convert various modules' type annotations + docstring examples to align with numpy.typing & fix linting
This commit is contained in:
 jirka authored and Jirka Borovec committed
1 parent
64acee9bec
commit
6c2c3f8862
8 files changed
+55
-32
No files matched your search
@@ -234,7 +234,8 @@ def mask_to_rle(mask: npt.NDArray[np.bool_]) -> list[int]:
|
||||
>>> [int(x) for x in rle]
|
||||
[5, 2, 2, 2, 5]
|
||||
|
||||
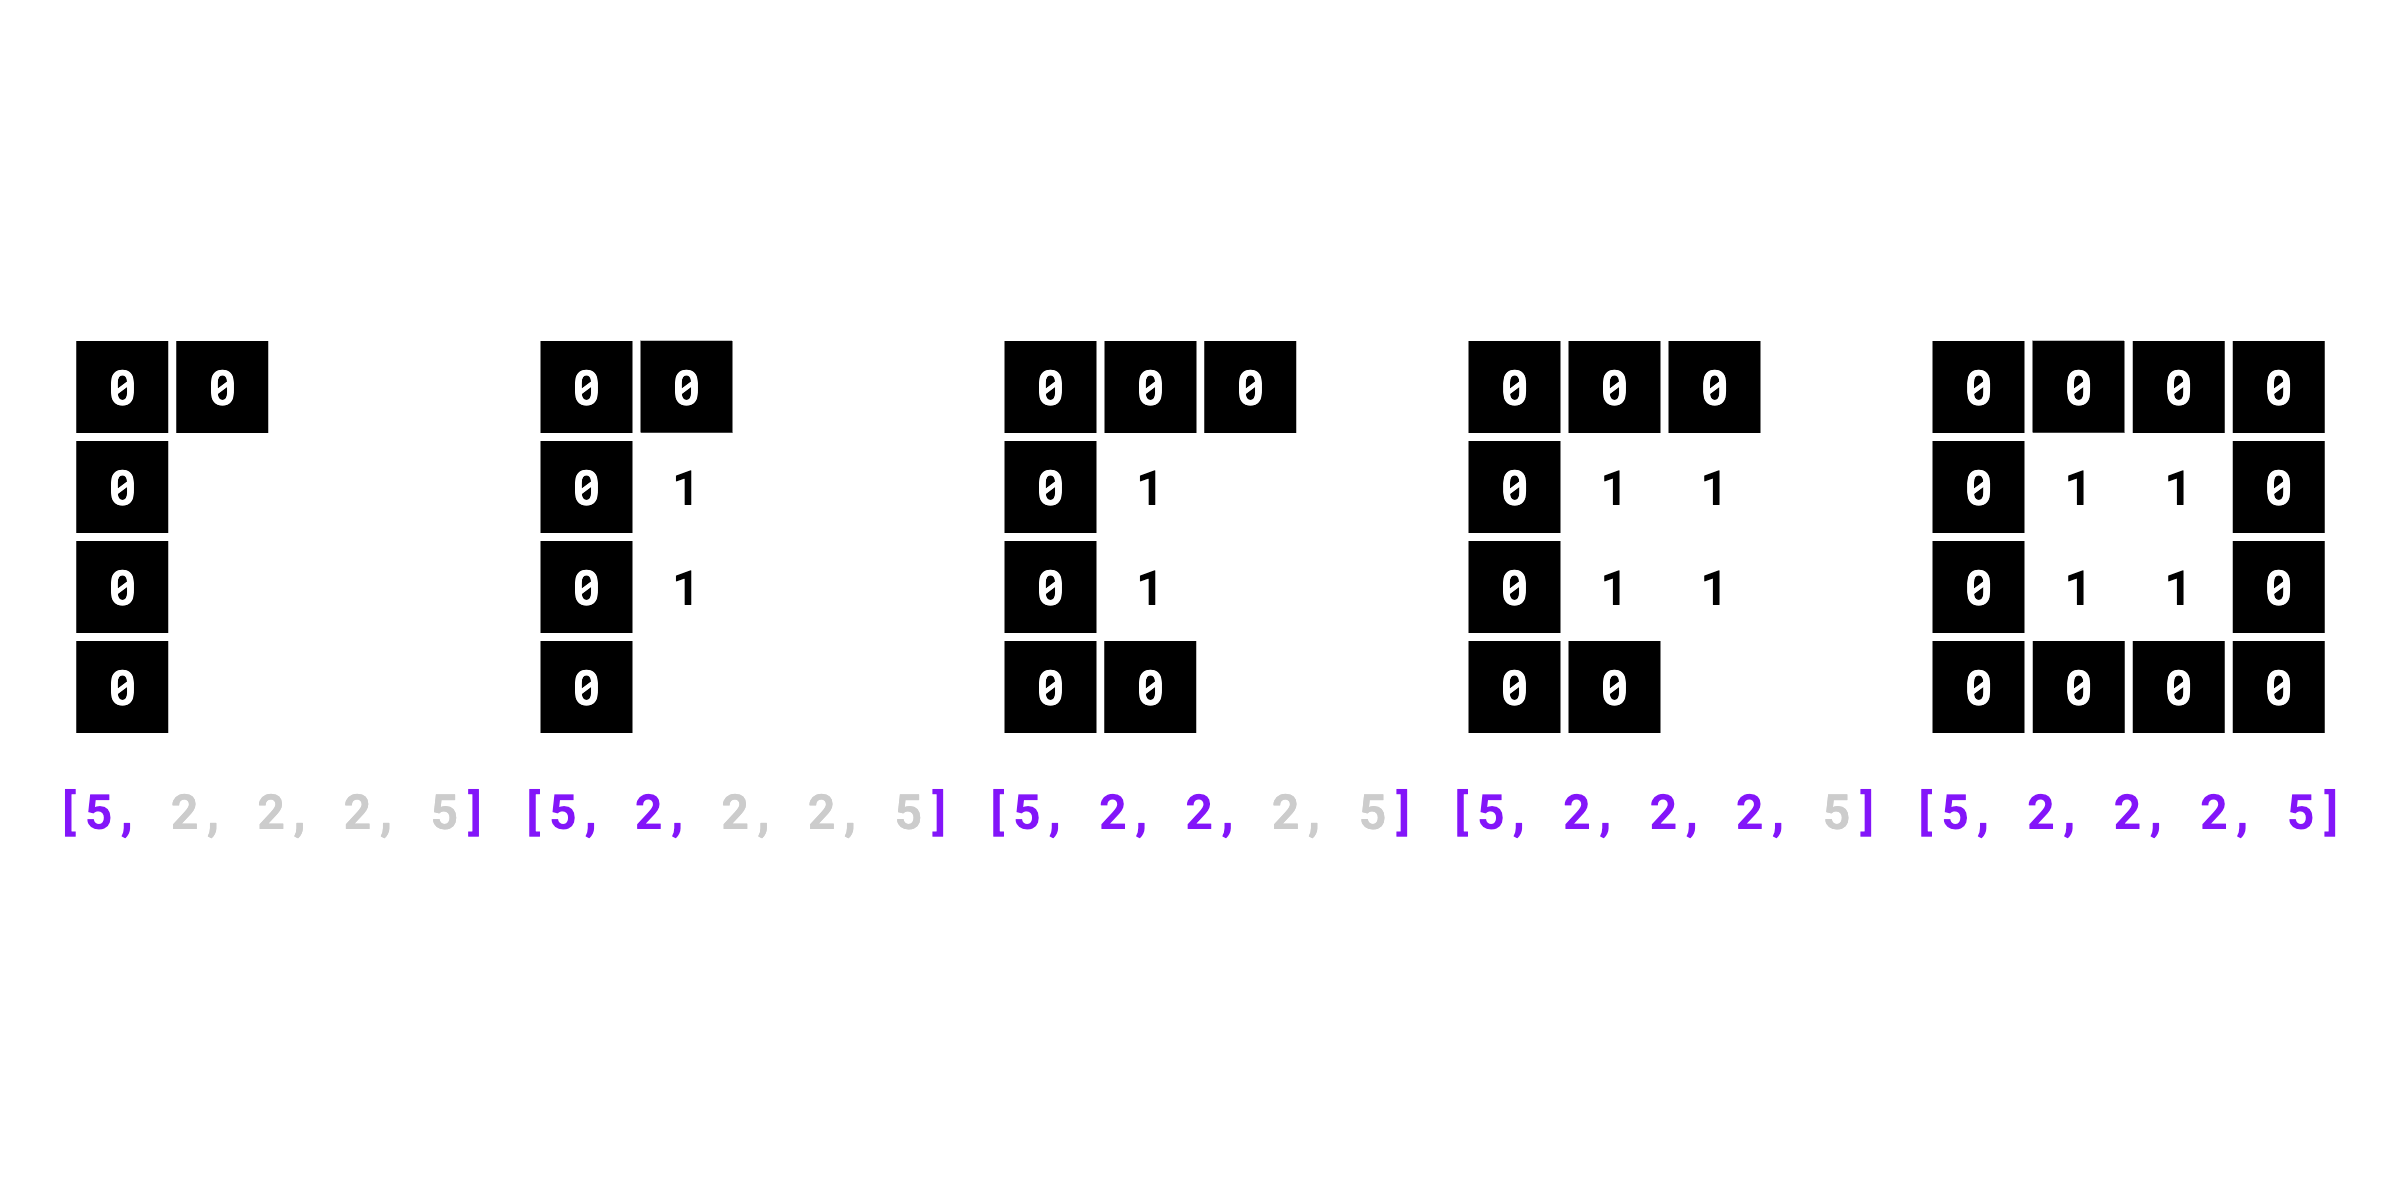{ align=center width="800" }
|
||||
{ align=center width="800" }
|
||||
"""
|
||||
assert mask.ndim == 2, "Input mask must be 2D"
|
||||
assert mask.size != 0, "Input mask cannot be empty"
|
||||
|
||||
@@ -45,7 +45,9 @@ class CSVSink:
|
||||
... class_id=np.array([0, 1])
|
||||
... )
|
||||
>>> # Use temporary file
|
||||
>>> temp_file = tempfile.NamedTemporaryFile(mode='w', suffix='.csv', delete=False)
|
||||
>>> temp_file = tempfile.NamedTemporaryFile(
|
||||
... mode='w', suffix='.csv', delete=False
|
||||
... )
|
||||
>>> temp_file.close()
|
||||
>>> csv_sink = sv.CSVSink(temp_file.name)
|
||||
>>> with csv_sink as sink:
|
||||
|
||||
@@ -194,10 +194,14 @@ def box_iou_batch(
|
||||
... [150, 150, 250, 250],
|
||||
... [320, 320, 420, 420]
|
||||
... ])
|
||||
>>> sv.box_iou_batch(boxes_true, boxes_detection, overlap_metric=sv.OverlapMetric.IOU)
|
||||
>>> sv.box_iou_batch(
|
||||
... boxes_true, boxes_detection, overlap_metric=sv.OverlapMetric.IOU
|
||||
... )
|
||||
array([[0.14285..., 0. ],
|
||||
[0. , 0.47058...]], dtype=float32)
|
||||
>>> sv.box_iou_batch(boxes_true, boxes_detection, overlap_metric=sv.OverlapMetric.IOS)
|
||||
>>> sv.box_iou_batch(
|
||||
... boxes_true, boxes_detection, overlap_metric=sv.OverlapMetric.IOS
|
||||
... )
|
||||
array([[0.25, 0. ],
|
||||
[0. , 0.64]], dtype=float32)
|
||||
"""
|
||||
|
||||
@@ -1,9 +1,10 @@
|
||||
from typing import TypeVar
|
||||
|
||||
import numpy as np
|
||||
import numpy.typing as npt
|
||||
from PIL import Image
|
||||
|
||||
ImageType = TypeVar("ImageType", np.ndarray, Image.Image)
|
||||
ImageType = TypeVar("ImageType", npt.NDArray[np.uint8], Image.Image)
|
||||
"""
|
||||
An image of type `np.ndarray` or `PIL.Image.Image`.
|
||||
|
||||
|
||||
@@ -307,7 +307,8 @@ class ColorPalette:
|
||||
|
||||
Example:
|
||||
>>> import supervision as sv
|
||||
>>> sv.ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff']) # doctest: +ELLIPSIS
|
||||
>>> colors = ['#ff0000', '#00ff00', '#0000ff']
|
||||
>>> sv.ColorPalette.from_hex(colors) # doctest: +ELLIPSIS
|
||||
ColorPalette(colors=[Color(r=255, g=0, b=0), Color(r=0, g=255, b=0), ...])
|
||||
"""
|
||||
colors = [Color.from_hex(color_hex) for color_hex in color_hex_list]
|
||||
@@ -356,7 +357,8 @@ class ColorPalette:
|
||||
|
||||
Example:
|
||||
>>> import supervision as sv
|
||||
>>> color_palette = sv.ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
>>> colors = ['#ff0000', '#00ff00', '#0000ff']
|
||||
>>> color_palette = sv.ColorPalette.from_hex(colors)
|
||||
>>> color_palette.by_idx(1)
|
||||
Color(r=0, g=255, b=0)
|
||||
"""
|
||||
|
||||
+32
-20
@@ -5,18 +5,19 @@ from typing import cast
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
import numpy.typing as npt
|
||||
|
||||
from supervision.draw.color import Color
|
||||
from supervision.geometry.core import Point, Rect
|
||||
|
||||
|
||||
def draw_line(
|
||||
scene: np.ndarray,
|
||||
scene: npt.NDArray[np.uint8],
|
||||
start: Point,
|
||||
end: Point,
|
||||
color: Color = Color.ROBOFLOW,
|
||||
thickness: int = 2,
|
||||
) -> np.ndarray:
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""
|
||||
Draws a line on a given scene.
|
||||
|
||||
@@ -41,8 +42,11 @@ def draw_line(
|
||||
|
||||
|
||||
def draw_rectangle(
|
||||
scene: np.ndarray, rect: Rect, color: Color = Color.ROBOFLOW, thickness: int = 2
|
||||
) -> np.ndarray:
|
||||
scene: npt.NDArray[np.uint8],
|
||||
rect: Rect,
|
||||
color: Color = Color.ROBOFLOW,
|
||||
thickness: int = 2,
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""
|
||||
Draws a rectangle on an image.
|
||||
|
||||
@@ -66,8 +70,11 @@ def draw_rectangle(
|
||||
|
||||
|
||||
def draw_filled_rectangle(
|
||||
scene: np.ndarray, rect: Rect, color: Color = Color.ROBOFLOW, opacity: float = 1
|
||||
) -> np.ndarray:
|
||||
scene: npt.NDArray[np.uint8],
|
||||
rect: Rect,
|
||||
color: Color = Color.ROBOFLOW,
|
||||
opacity: float = 1,
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""
|
||||
Draws a filled rectangle on an image.
|
||||
|
||||
@@ -105,11 +112,11 @@ def draw_filled_rectangle(
|
||||
|
||||
|
||||
def draw_rounded_rectangle(
|
||||
scene: np.ndarray,
|
||||
scene: npt.NDArray[np.uint8],
|
||||
rect: Rect,
|
||||
color: Color,
|
||||
border_radius: int,
|
||||
) -> np.ndarray:
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""
|
||||
Draws a rounded rectangle on an image.
|
||||
|
||||
@@ -157,11 +164,11 @@ def draw_rounded_rectangle(
|
||||
|
||||
|
||||
def draw_polygon(
|
||||
scene: np.ndarray,
|
||||
polygon: np.ndarray,
|
||||
scene: npt.NDArray[np.uint8],
|
||||
polygon: npt.NDArray[np.int_],
|
||||
color: Color = Color.ROBOFLOW,
|
||||
thickness: int = 2,
|
||||
) -> np.ndarray:
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""Draw a polygon on a scene.
|
||||
|
||||
Parameters:
|
||||
@@ -180,11 +187,11 @@ def draw_polygon(
|
||||
|
||||
|
||||
def draw_filled_polygon(
|
||||
scene: np.ndarray,
|
||||
polygon: np.ndarray,
|
||||
scene: npt.NDArray[np.uint8],
|
||||
polygon: npt.NDArray[np.int_],
|
||||
color: Color = Color.ROBOFLOW,
|
||||
opacity: float = 1,
|
||||
) -> np.ndarray:
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""Draw a filled polygon on a scene.
|
||||
|
||||
Parameters:
|
||||
@@ -209,7 +216,7 @@ def draw_filled_polygon(
|
||||
|
||||
|
||||
def draw_text(
|
||||
scene: np.ndarray,
|
||||
scene: npt.NDArray[np.uint8],
|
||||
text: str,
|
||||
text_anchor: Point,
|
||||
text_color: Color = Color.BLACK,
|
||||
@@ -218,7 +225,7 @@ def draw_text(
|
||||
text_padding: int = 10,
|
||||
text_font: int = cv2.FONT_HERSHEY_SIMPLEX,
|
||||
background_color: Color | None = None,
|
||||
) -> np.ndarray:
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""
|
||||
Draw text with background on a scene.
|
||||
|
||||
@@ -246,7 +253,9 @@ def draw_text(
|
||||
>>> from supervision.draw.utils import draw_text
|
||||
>>> scene = np.zeros((100, 100, 3), dtype=np.uint8)
|
||||
>>> text_anchor = Point(x=50, y=50)
|
||||
>>> scene = draw_text(scene=scene, text="Hello, world!", text_anchor=text_anchor)
|
||||
>>> scene = draw_text(
|
||||
... scene=scene, text="Hello, world!", text_anchor=text_anchor
|
||||
... )
|
||||
>>> scene.shape
|
||||
(100, 100, 3)
|
||||
"""
|
||||
@@ -285,8 +294,11 @@ def draw_text(
|
||||
|
||||
|
||||
def draw_image(
|
||||
scene: np.ndarray, image: str | np.ndarray, opacity: float, rect: Rect
|
||||
) -> np.ndarray:
|
||||
scene: npt.NDArray[np.uint8],
|
||||
image: str | npt.NDArray[np.uint8],
|
||||
opacity: float,
|
||||
rect: Rect,
|
||||
) -> npt.NDArray[np.uint8]:
|
||||
"""
|
||||
Draws an image onto a given scene with specified opacity and dimensions.
|
||||
|
||||
@@ -329,7 +341,7 @@ def draw_image(
|
||||
|
||||
# Resize and isolate alpha channel
|
||||
image = cv2.resize(image, (rect_width, rect_height))
|
||||
image = cast(np.ndarray, image)
|
||||
image = cast(npt.NDArray[np.uint8], image)
|
||||
alpha_channel = (
|
||||
image[:, :, 3]
|
||||
if image.shape[2] == 4
|
||||
|
||||
@@ -1,9 +1,10 @@
|
||||
import numpy as np
|
||||
import numpy.typing as npt
|
||||
|
||||
from supervision.geometry.core import Point
|
||||
|
||||
|
||||
def get_polygon_center(polygon: np.ndarray) -> Point:
|
||||
def get_polygon_center(polygon: npt.NDArray[np.float64]) -> Point:
|
||||
"""
|
||||
Calculate the center of a polygon. The center is calculated as the center
|
||||
of the solid figure formed by the points of the polygon
|
||||
|
||||
@@ -113,7 +113,7 @@ def scale_image(image: ImageType, scale_factor: float) -> ImageType:
|
||||
width_old, height_old = image.shape[1], image.shape[0]
|
||||
width_new = int(width_old * scale_factor)
|
||||
height_new = int(height_old * scale_factor)
|
||||
return cv2.resize(image, (width_new, height_new), interpolation=cv2.INTER_LINEAR) # type: ignore
|
||||
return cv2.resize(image, (width_new, height_new), interpolation=cv2.INTER_LINEAR)
|
||||
|
||||
|
||||
@ensure_cv2_image_for_standalone_function
|
||||
@@ -170,7 +170,7 @@ def resize_image(
|
||||
else:
|
||||
width_new, height_new = resolution_wh
|
||||
|
||||
return cv2.resize(image, (width_new, height_new), interpolation=cv2.INTER_LINEAR) # type: ignore
|
||||
return cv2.resize(image, (width_new, height_new), interpolation=cv2.INTER_LINEAR)
|
||||
|
||||
|
||||
@ensure_cv2_image_for_standalone_function
|
||||
@@ -233,7 +233,7 @@ def letterbox_image(
|
||||
image[:, :padding_left, 3] = 0
|
||||
image[:, width_new - padding_right :, 3] = 0
|
||||
|
||||
return image_with_borders # type: ignore
|
||||
return image_with_borders
|
||||
|
||||
|
||||
@deprecated(
|
||||
@@ -378,7 +378,7 @@ def grayscale_image(image: ImageType) -> ImageType:
|
||||
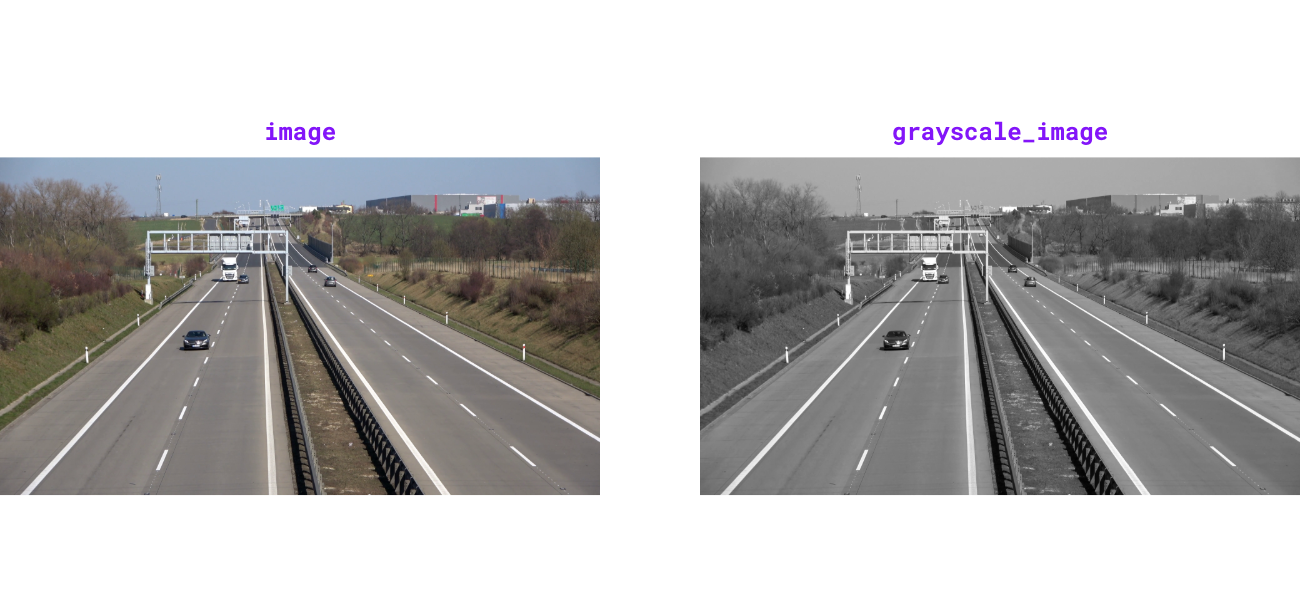{ align=center width="1000" }
|
||||
""" # noqa E501 // docs
|
||||
grayscaled = cv2.cvtColor(image, cv2.COLOR_BGR2GRAY)
|
||||
return cv2.cvtColor(grayscaled, cv2.COLOR_GRAY2BGR) # type: ignore
|
||||
return cv2.cvtColor(grayscaled, cv2.COLOR_GRAY2BGR)
|
||||
|
||||
|
||||
def get_image_resolution_wh(image: ImageType) -> tuple[int, int]:
|
||||
|
||||
Reference in new issue
Block a user