Merge pull request #1000 from roboflow/0.19.0-changelog
`supervision-0.19.0` release changelog
This commit is contained in:

3 files changed
+84
-7
No files matched your search
@@ -293,12 +293,6 @@ status: new
|
||||
)
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
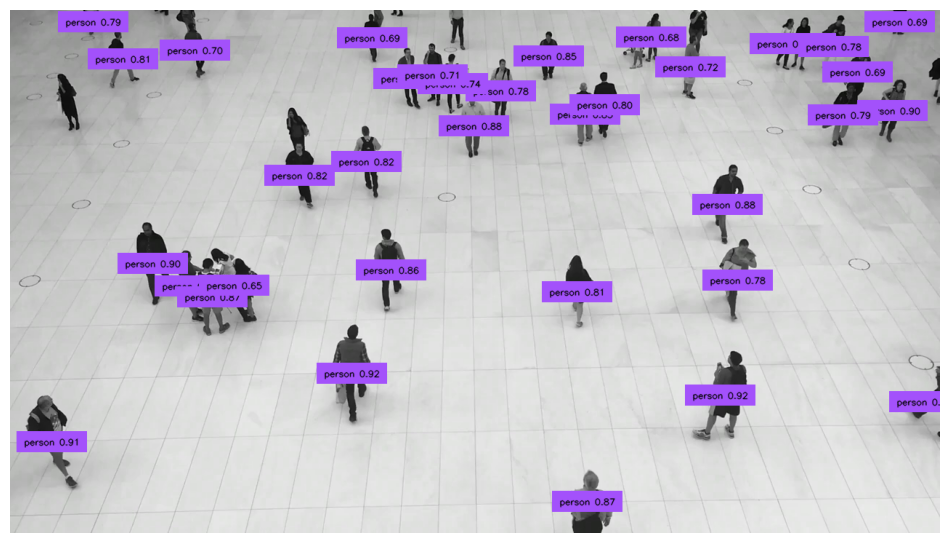{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
=== "Blur"
|
||||
|
||||
```python
|
||||
|
||||
+83
-1
@@ -1,6 +1,88 @@
|
||||
### 0.19.0 <small>March 15, 2024</small>
|
||||
|
||||
- Added [#818](https://github.com/roboflow/supervision/pull/818): [`sv.CSVSink`](/0.19.0/detection/tools/save_detections/#supervision.detection.tools.csv_sink.CSVSink) allowing for the straightforward saving of image, video, or stream inference results in a `.csv` file.
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO(<SOURCE_MODEL_PATH>)
|
||||
csv_sink = sv.CSVSink(<RESULT_CSV_FILE_PATH>)
|
||||
frames_generator = sv.get_video_frames_generator(<SOURCE_VIDEO_PATH>)
|
||||
|
||||
with csv_sink:
|
||||
for frame in frames_generator:
|
||||
result = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(result)
|
||||
csv_sink.append(detections, custom_data={<CUSTOM_LABEL>:<CUSTOM_DATA>})
|
||||
```
|
||||
|
||||
- Added [#819](https://github.com/roboflow/supervision/pull/819): [`sv.JSONSink`](/0.19.0/detection/tools/save_detections/#supervision.detection.tools.csv_sink.JSONSink) allowing for the straightforward saving of image, video, or stream inference results in a `.json` file.
|
||||
|
||||
```python
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO(<SOURCE_MODEL_PATH>)
|
||||
json_sink = sv.JSONSink(<RESULT_JSON_FILE_PATH>)
|
||||
frames_generator = sv.get_video_frames_generator(<SOURCE_VIDEO_PATH>)
|
||||
|
||||
with json_sink:
|
||||
for frame in frames_generator:
|
||||
result = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(result)
|
||||
json_sink.append(detections, custom_data={<CUSTOM_LABEL>:<CUSTOM_DATA>})
|
||||
```
|
||||
|
||||
- Added [#847](https://github.com/roboflow/supervision/pull/847): [`sv.mask_iou_batch`](/0.19.0/detection/utils/#supervision.detection.utils.mask_iou_batch) allowing to compute Intersection over Union (IoU) of two sets of masks.
|
||||
|
||||
- Added [#847](https://github.com/roboflow/supervision/pull/847): [`sv.mask_non_max_suppression`](/0.19.0/detection/utils/#supervision.detection.utils.mask_non_max_suppression) allowing to perform Non-Maximum Suppression (NMS) on segmentation predictions.
|
||||
|
||||
- Added [#888](https://github.com/roboflow/supervision/pull/888): [`sv.CropAnnotator`](/0.19.0/annotators/#supervision.annotators.core.CropAnnotator) allowing users to annotate the scene with scaled-up crops of detections.
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
model = get_model(model_id="yolov8n-640")
|
||||
|
||||
result = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(result)
|
||||
|
||||
crop_annotator = sv.CropAnnotator()
|
||||
annotated_frame = crop_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
)
|
||||
```
|
||||
|
||||
- Changed [#827](https://github.com/roboflow/supervision/pull/827): [`sv.ByteTrack.reset`](/0.19.0/tracking/#supervision.tracking.ByteTrack.reset) allowing users to clear trackers state, enabling the processing of multiple video files in sequence.
|
||||
|
||||
- Changed [#802](https://github.com/roboflow/supervision/pull/802): [`sv.LineZoneAnnotator`](/0.19.0/detection/tools/line_zone/#supervision.detection.line_zone.LineZone) allowing to hide in/out count using `display_in_count` and `display_out_count` properties.
|
||||
|
||||
- Changed [#787](https://github.com/roboflow/supervision/pull/787): [`sv.ByteTrack`](/0.19.0/tracking/#supervision.tracking.ByteTrack) input arguments and docstrings updated to improve readability and ease of use.
|
||||
|
||||
!!! failure "Deprecated"
|
||||
|
||||
The `track_buffer`, `track_thresh`, and `match_thresh` parameters in `sv.ByterTrack` are deprecated and will be removed in `supervision-0.23.0`. Use `lost_track_buffer,` `track_activation_threshold`, and `minimum_matching_threshold` instead.
|
||||
|
||||
- Changed [#910](https://github.com/roboflow/supervision/pull/910): [`sv.PolygonZone`](/0.19.0/detection/tools/polygon_zone/#supervision.detection.tools.polygon_zone.PolygonZone) to now accept a list of specific box anchors that must be in zone for a detection to be counted.
|
||||
|
||||
!!! failure "Deprecated"
|
||||
|
||||
The `triggering_position ` parameter in `sv.PolygonZone` is deprecated and will be removed in `supervision-0.23.0`. Use `triggering_anchors` instead.
|
||||
|
||||
- Changed [#875](https://github.com/roboflow/supervision/pull/875): annotators adding support for Pillow images. All supervision Annotators can now accept an image as either a numpy array or a Pillow Image. They automatically detect its type, draw annotations, and return the output in the same format as the input.
|
||||
|
||||
- Fixed [#944](https://github.com/roboflow/supervision/pull/944): [`sv.DetectionsSmoother`](/0.19.0/detection/tools/smoother/#supervision.detection.tools.smoother.DetectionsSmoother) removing `tracking_id` from `sv.Detections`.
|
||||
|
||||
### 0.18.0 <small>January 25, 2024</small>
|
||||
|
||||
- Added [#633](https://github.com/roboflow/supervision/pull/720): [`sv.PercentageBarAnnotator`](/0.18.0/annotators/#percentagebarannotator) allowing to annotate images and videos with percentage values representing confidence or other custom property.
|
||||
- Added [#720](https://github.com/roboflow/supervision/pull/720): [`sv.PercentageBarAnnotator`](/0.18.0/annotators/#percentagebarannotator) allowing to annotate images and videos with percentage values representing confidence or other custom property.
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
@@ -1859,6 +1859,7 @@ class CropAnnotator(BaseAnnotator):
|
||||
self.position: Position = position
|
||||
self.scale_factor: int = scale_factor
|
||||
|
||||
@scene_to_annotator_img_type
|
||||
def annotate(
|
||||
self,
|
||||
scene: np.ndarray,
|
||||
|
||||
Reference in new issue
Block a user